Figure 1:Blind Adversary statement banner.
1. Introduction
Hide and Seek Arena aims to help students understand, implement, and optimize search algorithms through an automated arena that simulates the game of hide and seek, where student teams can compete against one another for ranking.
In this assignment, we introduce partial observability. Agents do not have access to the full map at each step, so each agent must plan and act using only a local field of view.
Each student team will develop both of the following agents:
Hide agent: Hide for as long as possible under limited vision.
Seek agent: Find and catch as quickly as possible under limited vision.
The agents will be automatically matched in the Arena to compute win rates and rankings.
2. Arena
The Arena is an automated framework, implemented in Python, that serves as the competitive environment for the agents. Given the teams’ submissions, the Arena will automatically import each team’s agents, run a series of matches between teams, and output the results.
2.1 Overview
The model of the Arena is illustrated as below:
Algorithm 1  Agent Environment Interaction Loop
1: while episode not terminated do
2:     ap ← PacmanAgent.step()
3:     ag ← GhostAgent.step()
4:     Environment.step(ap, ag)
5:     Update agent positions
6:     Check collisions or termination
7:     s ← observe new environment state with partial observability
8: end while
At each step in Algorithm 1, the provided information includes:
map state: A partial 21 × 21 map observation representing the local field of view.
my position: The agent’s current position with coordinates
xandy.enemy position: The opponent’s position if it is visible, otherwise
None.step number: The current step count.
2.2 Partial Observability and Local View Representation
To construct the map state mentioned above, the Arena restricts what the agent can
perceive based on its current coordinates x and y. Rather than seeing the entire
board, the agent is limited to a cross-shaped local field of view. This grants the
agent sight of its current cell along with up to 5 cells outward in the four
cardinal directions: Up, Down, Left, and Right. These four vision rays represent the
agent’s line of sight, but they are strictly blocked by any non-traversable obstacles.
The moment a wall is encountered, visibility in that specific direction stops
completely, hiding all cells behind the wall.
# # # # # # # # # # # # # # # # # # # # #
# . . . . . . . . . # . . . . . . . . . #
# . # # # . # # # . # . # # # . # # # . #
# . # # # . # # # . # . # # # . # # # . #
# . . . . . . . . . . . . . . . . . . . #
# . # # # . # . # # # # # . # . # # # . #
# . . . . . # . . . # . . . # . . . . . #
# # # # # . # # # . # . # # # . # # # # #
# # # # # . # . . . G . . . # . # # # # #
# # # # # . # . # # . # # . # . # # # # #
# . . . . . . . # . . . # . . . . . . . #
# # # # # . # . # # # # # . # . # # # # #
# # # # # . # . . . . . . . # . # # # # #
# # # # # . # . # # # # # . # . # # # # #
# . . . . . . . . . # . . . . . . . . . #
# . # # # . # # # . # . # # # . # # # . #
# . . . # . . . . . P . . . . . # . . . #
# # # . # . # . # # # # # . # . # . # # #
# . . . . . # . . . # . . . # . . . . . #
# . # # # # # # # . # . # # # # # # # . #
# . . . . . . . . . . . . . . . . . . . #
# # # # # # # # # # # # # # # # # # # # #
Figure 1: Arena map with P for Pacman, G for Ghost, # for Walls, and . for Empty pathThe Arena packages this limited vision into a masked 21 × 21 grid so the agent can programmatically process what is known and what remains hidden. Within this grid:
wall cells are always visible and are marked as
1.The empty paths that fall within the agent’s line of sight are marked as
0.any empty space outside this observable region is encoded as
−1to indicate unknown territory.
When designing the planning logic, student teams must ensure their agents treat all
−1 cells as completely unknown and never blindly assume they are safe to traverse.
Similar to the non-blind mode, both agents act simultaneously but may receive different
observations due to their positions and limited visibility.
The win conditions are defined as follows:
The Seek agent wins: if the Seek agent touches the Hide agent with a Manhattan distance strictly less than 2.
The Hide agent wins: if the maximum number of allowed steps is reached.
Please note that the framework is provided to you for reference, and evaluating your own agent against the above conditions may require some tweakings.
The source code of this framework is provided as pacman.zip in the
Google Drive folder.
The source code will be provided to students with the following directory
structure:
Arena/
├── src/                       # Framework source code, do NOT modify
├── submissions/               # Student workspace
│   ├── example_student/
│   │   └── agent.py           # Reference implementation
│   ├── <student id>/
│   │   └── agent.py           # Student team agent
│   ├── STUDENT_GUIDE.md       # Student instructions
│   └── run_game.sh            # Quick run script
Besides that, the given folder also includes a Blind folder featuring selected instances of previous courses where the top submissions are sampled. About the speed: if both agents move at the same speed, the Seek Agent can never win because it cannot make contact with the Hide Agent. To ensure fairness, the Seek Agent moves at a speed of 2 cells per step when moving in a straight line but cannot move with an L-shape immediately during a turn.
At each step, a student team’s agent must return an action in the following format:
class AgentInterface(ABC):
    @abstractmethod
    def step(self, map_state, my_position, enemy_position, step_number):
        # Planning under partial observability
        # For Pacman Agent: return a Move or a tuple of Move and steps, where:
        #   steps is an int from 1 to the configured max straight-line speed.
        # For Ghost Agent: return a Move such as UP, DOWN, LEFT, RIGHT, or STAY.
The recommended algorithms are: Minimax, Monte Carlo, Alpha-beta Pruning, Expectiminimax, etc., adapted for partial observability. Student teams must ensure that their agent returns an action within a maximum of 1 second.
3. Tournament
Each team will participate in both roles, Hide and Seek, and will compete against the agents of all other teams. Based on the outcomes, the win rates are computed as:
The results are recorded in the following example table.
| Hide \ Seek | Team 1 | Team 2 | Team 3 | Team 4 |
|---|---|---|---|---|
| Team 1 | – | 0 | 1 | 1 |
| Team 2 | 0 | – | 1 | 0 |
| Team 3 | 1 | 0 | – | 1 |
| Team 4 | 0 | 0 | 1 | – |
Here, a value of 0 denotes a Hide win, while a value of 1 denotes a Seek win.
Based on the table above, an example of the win rates for Team 1 is as follows:
As the Hide agent, Team 1 wins 1 out of 3 matches, resulting in .
As the Seek agent, Team 1 wins 2 out of 3 matches, resulting in .
Note that, besides the raw winning result, we also record your agent’s average steps required to end each match. For Pacman, you should also minimize this value, while for Ghost, you should also maximize this value. In order to tie-break teams with similar winning rates, we evaluate their difference between Pacman’s and Ghost’s average steps, where the one with the lower difference ranks higher.
The scoring criteria for each team is defined as follows:
| Criterion | Score |
|---|---|
| Algorithm implementation completeness | 3 |
| Ranking in the initial submission, detailed in the timeline in Section 4 | Up to 3 |
| Ranking in the optimized submission, detailed in the timeline in Section 4 | Up to 4 |
4. Submission
Each team must submit a single <group id>.zip file to Moodle containing the
following directory structure, where <group id> denotes a single, no zero-leading,
integer for your group’s ID only. For example please use 1.zip INSTEAD of
group 1.zip or group 01.zip. The general structure of your submitted zip folder
should be:
<group id>/
├── agent.py
└── etc.
The submitted agent is allowed to import other files located within the same
submission directory. The allowed extensions for storing ML models’ weights are:
.onnx, .pt/.pth, .npy/.npz.
The submission timeline is specified as follows:
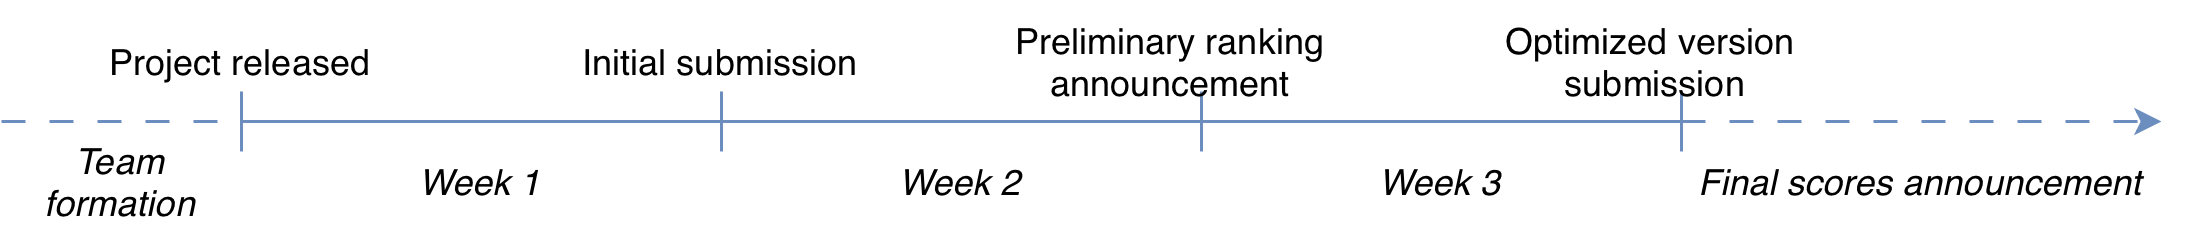
Figure 2:Statement submission timeline (initial and optimized submission phases).
5. Notices
Please pay attention to the following notices:
This is a GROUP assignment.
Late submissions will not be accepted under any circumstances.
This project has two submission phases. Only teams that submitted in the first phase are allowed to submit in the second phase.
Student teams must ensure that their agent returns an action within a maximum of 1 second while consuming at most 128 MB under the setting of Google Colab’s CPU-only instance, where the grading hardware is kept fixed on this configuration for a stable environment and the most reproducible results. The allowed libraries are already installed on that instance, so do not submit a
requirements.txt. The built-intimelibrary may be used together with all built-in libraries bundled with Python 3. External libraries available for your team include:numpy,pandas,scipy,gurobi,pytorch, andscikit-learn, together with all of their dependencies in an environment of Python 3.11.AI tools are NOT restricted, but students should use them wisely. Lab instructors have the right to conduct additional oral interviews to assess their knowledge of the project.
Any form of plagiarism, dishonesty, or misconduct will result in a grade of zero for the course.
The end.